Maker.io main logo

Projects Ver todo

PROJECT
1,125

Adding Object Detection Vision to the XRP Robot

By ShawnHymel

This guide demonstrates how to add a custom object detection machine learning model to the XRP robot.

PROJECT
1,519

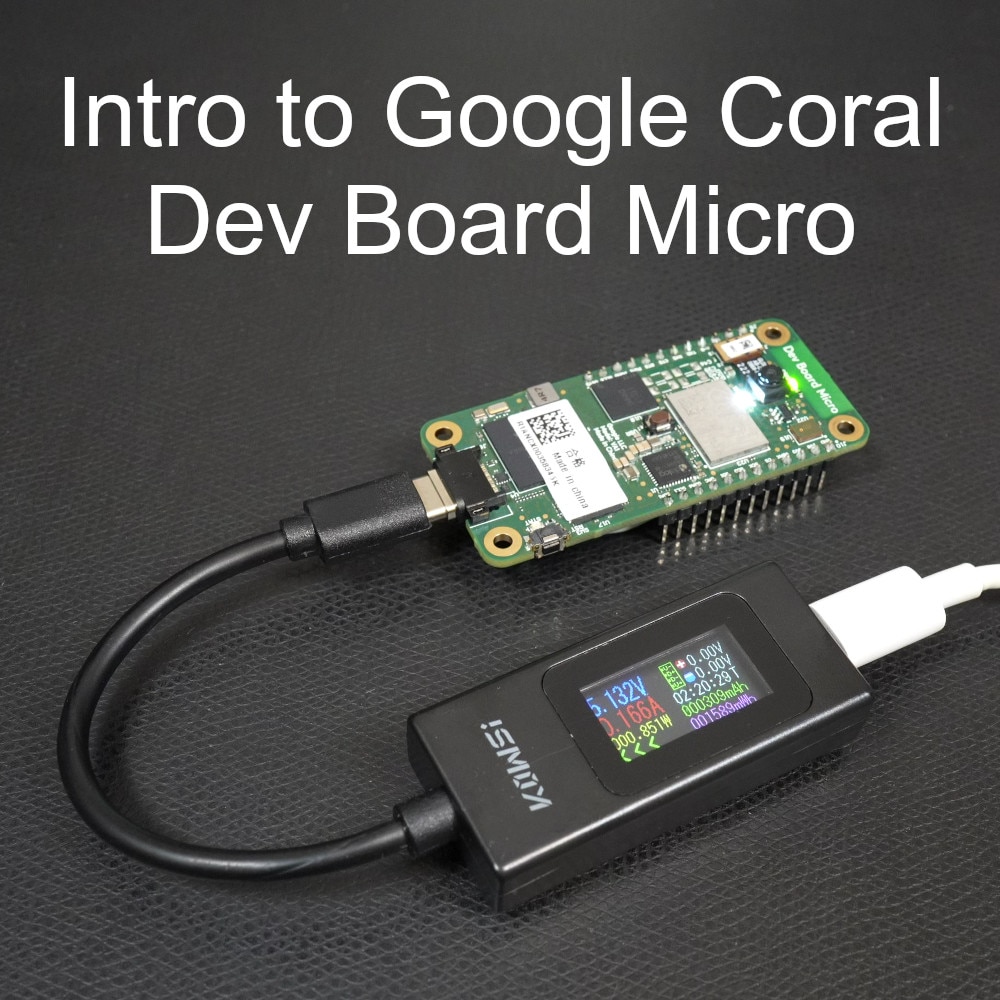
Intro to the Google Coral Dev Board Micro: Custom Object Detection

By ShawnHymel

This tutorial demonstrates how to train and deploy a custom object detection model for the Google Coral Dev Board Micro.

PROJECT
1,127

Tiny Reinforcement Learning (TinyRL) for Robotics

By ShawnHymel

This project demonstrates using reinforcement learning to solve the swing-up problem on an inverted pendulum

PROJECT
345

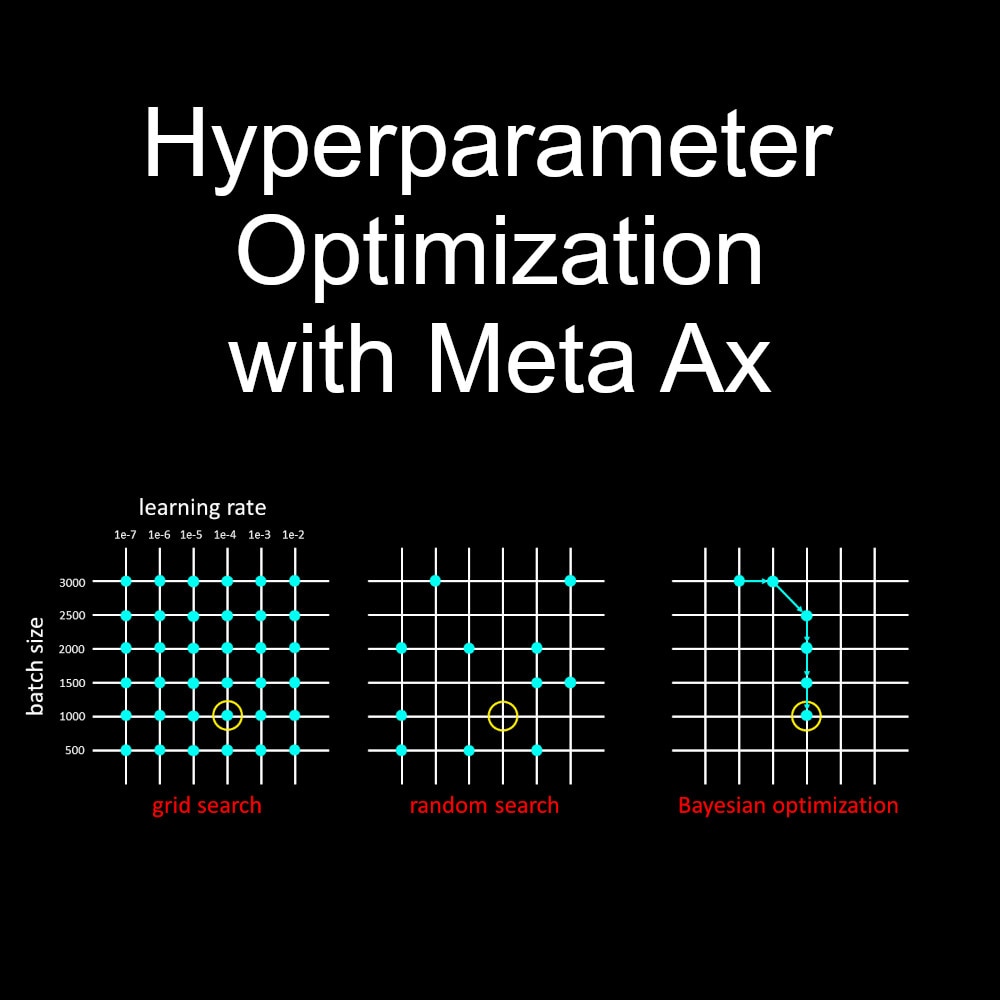
Hyperparameter Optimization with Meta Ax

By ShawnHymel

This tutorial demonstrates hyperparameter tuning using Meta's Ax framework for a common reinforcement learning problem

PROJECT
5,555

How to Tune a PID Controller

By ShawnHymel

In this tutorial, we demonstrate how to manually tune a PID controller.

PROJECT
9,469

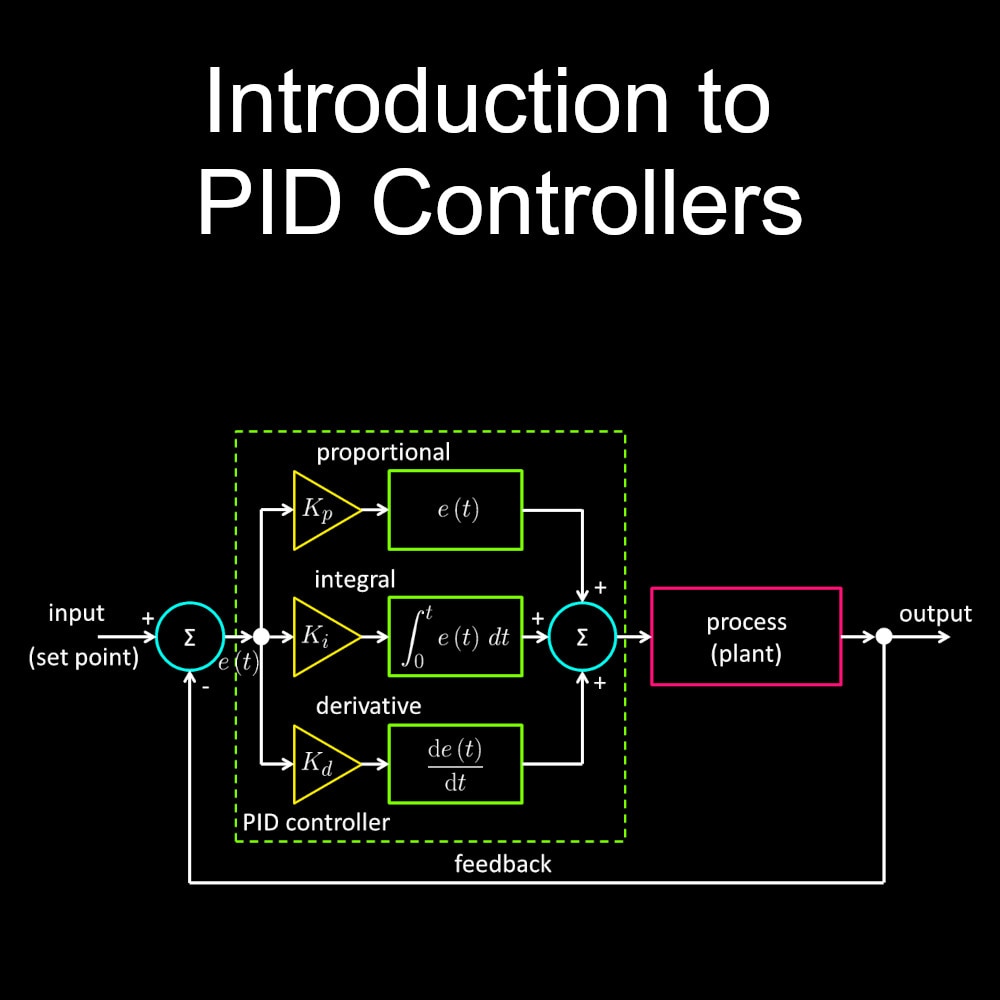
Introduction to PID Controllers

By ShawnHymel

In this post, we cover the basic theory behind PID controllers. PID stands for “Proportional, Integral, Derivative," and they are commonly used in industrial settings to control various processes.

Blogs

BLOG
766

Digit: A Wearable Companion Bot with AI Voice Interaction

By ShawnHymel

Digit's AI-powered brain enables local real-time voice conversations using Hopper Chat and Llama 3. Learn how to set it up with NVIDIA Jetson Orin Nano.

Tutorials Ver todo

TUTORIAL
14

Intro to LoRa Mesh Part 2: Getting Started with Meshtastic

By ShawnHymel

This time we get hands-on: flashing three nodes with the Meshtastic firmware, configuring them through the phone app, and sending our first broadcast, direct, and encrypted channel messages.

TUTORIAL
122

Intro to LoRa Mesh Part 1: Meshtastic vs. MeshCore

By ShawnHymel

In this first part, I want to cover what LoRa is, how mesh networking works, and how the two protocols differ, along with the hardware I will use for the rest of the series.

TUTORIAL
232

Reinforcement Learning for Robotics Part 6: AI-Powered RC Balance Bot

By ShawnHymel

In this episode, we deploy the trained agent to the real robot and build a web-based remote controller.

TUTORIAL
156

Reinforcement Learning for Robotics Part 5: Adding Commands to the Agent

By ShawnHymel

In this post, we demonstrate how to implement domain randomization with reinforcement learning (using the PPO algorithm) to balance a 2-wheel robot.

TUTORIAL
173

Reinforcement Learning for Robotics Part 4: Domain Randomization

By ShawnHymel

In this post, we demonstrate how to implement domain randomization with reinforcement learning (using the PPO algorithm) to balance a 2-wheel robot.

TUTORIAL
258

Reinforcement Learning for Robotics Part 3: Deploy AI Agent to a Robot

By ShawnHymel

In this post, we'll show how to deploy a trained actor neural network from a PPO agent to an ESP32 robot using Arduino.